Selected Work
Production systems, research, and selected technical projects.
I design, train, and deploy neural perception systems. As technical owner of three ML/CV systems, I build the models, data pipelines, distributed training, and onboard inference that turn geometric learning into measurable results. My shared calibration-data pipeline streamed 17+ TB of raw logs in a single pass to produce ~600 GB of data for both calibration models.
Industry Systems
Neural Sensor Calibration Systems
Two neural calibration systems designed, trained, and deployed end to end: cross-modal attention and camera conditioning for camera–LiDAR geometry, and shared spherical features with circular correlation for cross-LiDAR alignment.
Neural Camera–LiDAR Calibration
Designed, trained, and deployed a 6-DoF camera–LiDAR calibration network with dual encoders, camera-conditioned FiLM, and cross-modal attention. On an unseen vehicle, the deployed model reduced rotation error by 95% (2.95° → 0.14°) and reprojection error by 89% (22.4 → 2.4 px).

Neural LiDAR–LiDAR Calibration
Built a LiDAR–LiDAR calibration network from scratch with shared spherical encoders, circular azimuth correlation, and sensor-conditioned rotation/translation heads. Deployed the model onboard, reducing fleet rotation error by 63% (0.93° → 0.35°).

In-Cabin Occupant Perception
Front- and rear-seat occupant monitoring built from RTMO detector/keypoint fine-tuning and a ResNet-18 multi-task occupancy/posture network, then integrated with iToF seating position, VLM temporal fusion, and confidence-aware vehicle messaging.

Research & Selected Projects
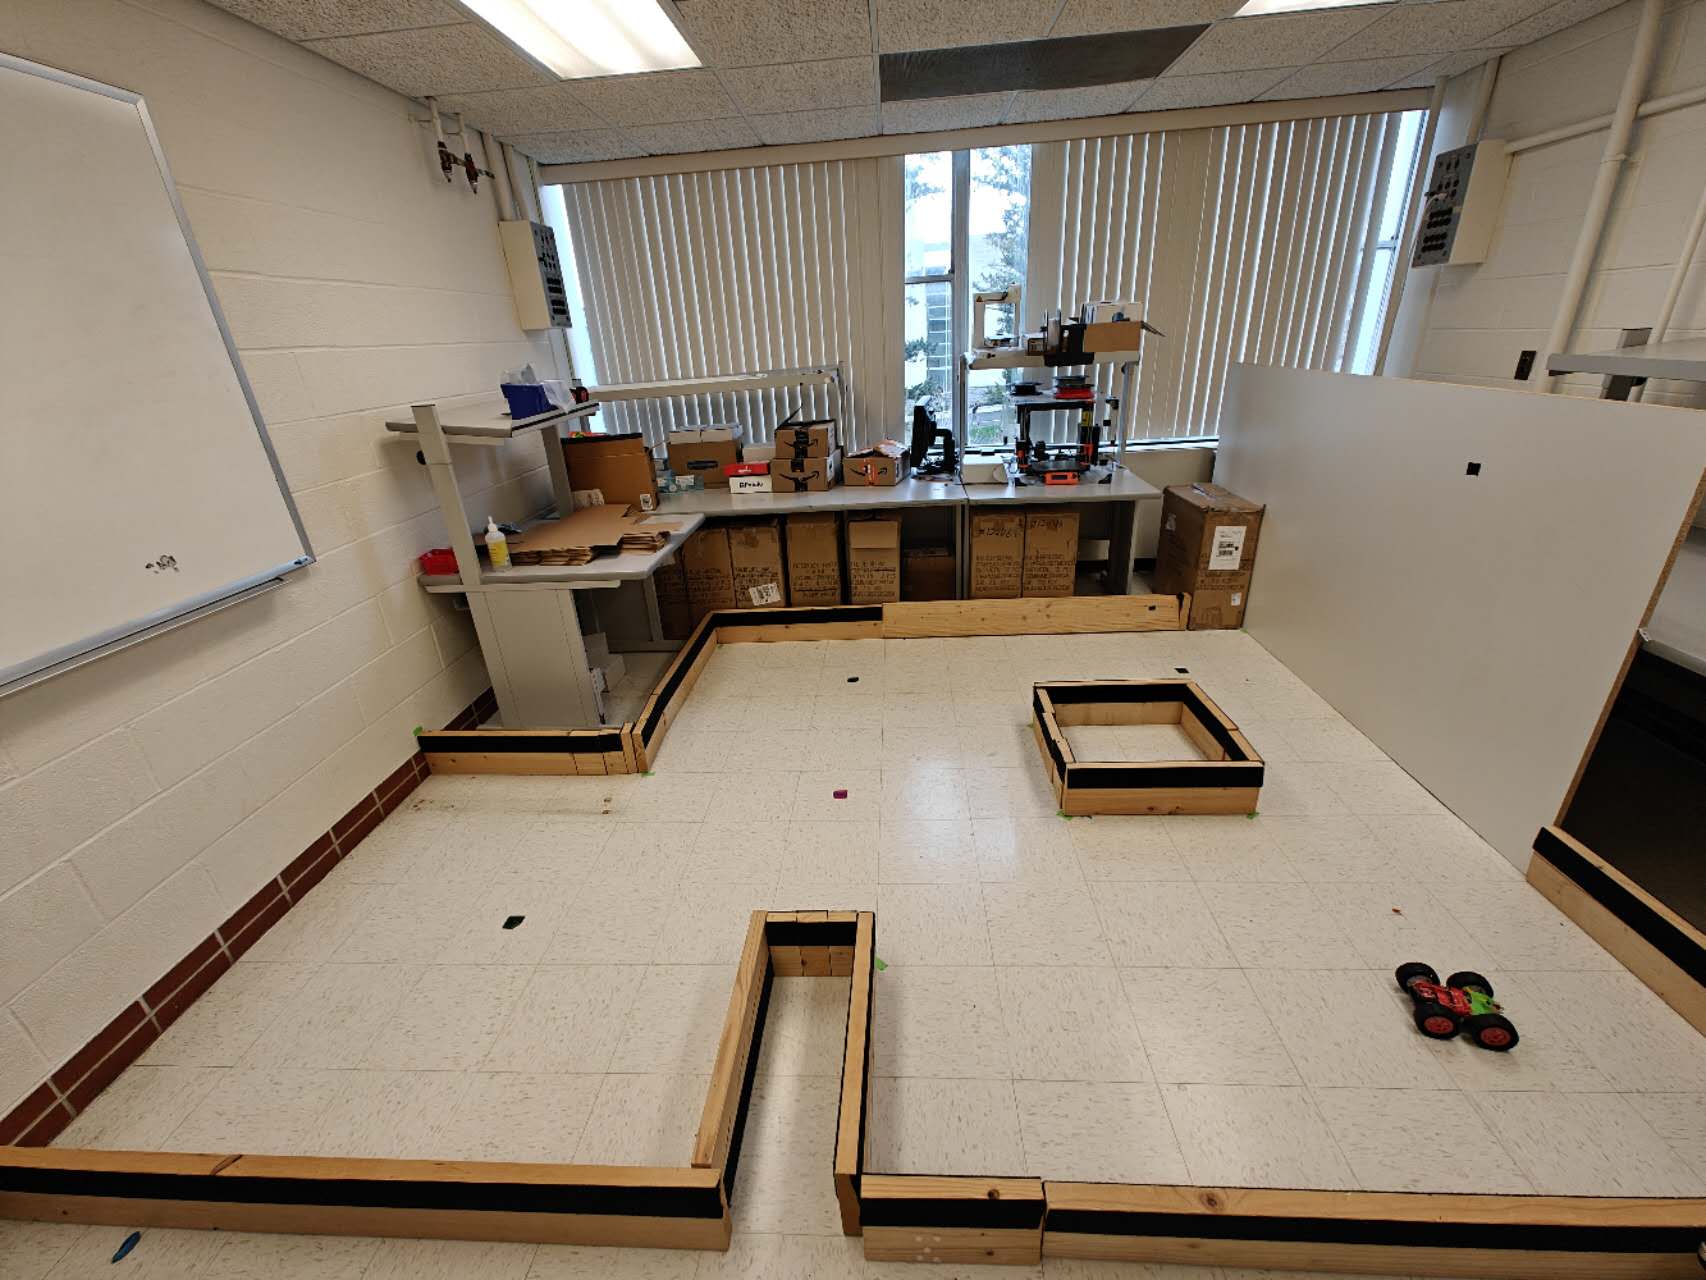
Fast Robot Navigation & Control
Embedded Systems & Robotics
Real-time navigation, control, and obstacle avoidance on a resource-constrained embedded robot.
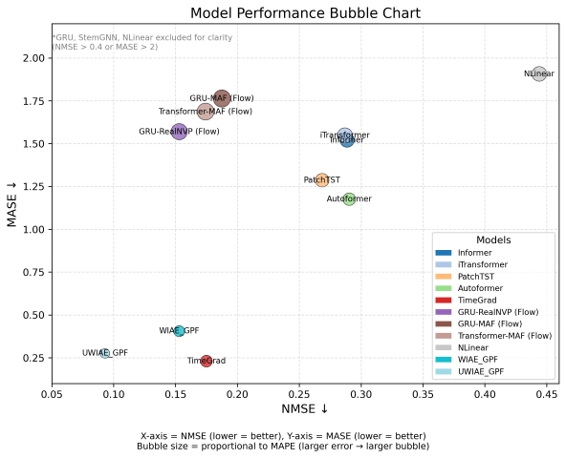
Point Forecasts to Probability Clouds — Probabilistic Electricity Price Forecasting
Research Project
Generative probabilistic forecasting of day-ahead electricity prices with calibrated uncertainty
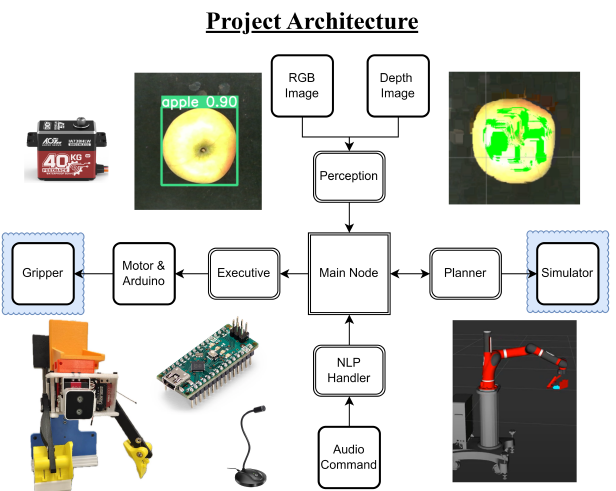
Robotic Tool Handler
Technical Project
Senior Design Project - ARM Cortex-based robotic system with real-time control
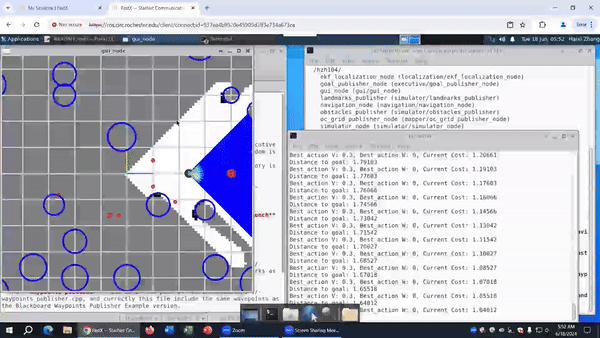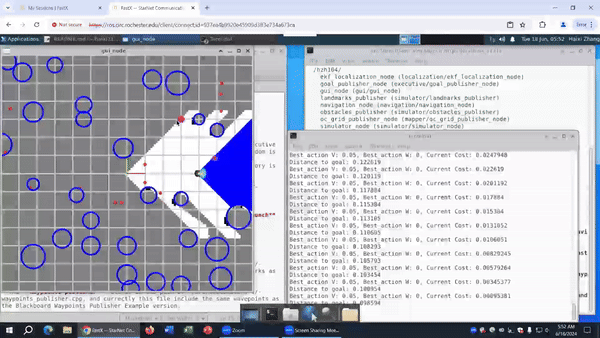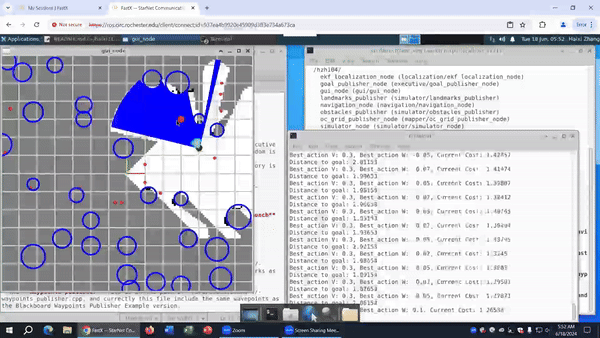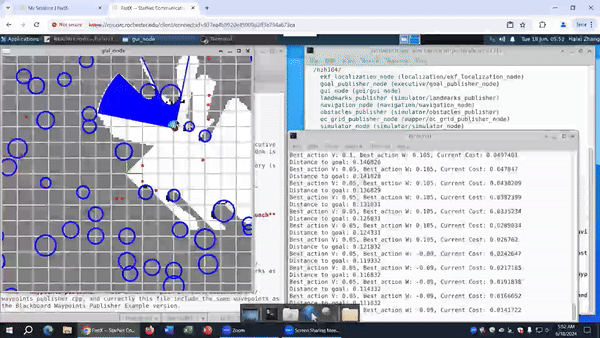
Robot Mapping, Estimation, and Interaction
Technical Project
Autonomous navigation system with SLAM capabilities for TurtleBot2
LRHPerception - Monocular Real-time Perception for Autonomous Driving
Research Project
Unified perception pipeline achieving 29 FPS with object tracking, trajectory prediction, road segmentation, and depth estimation
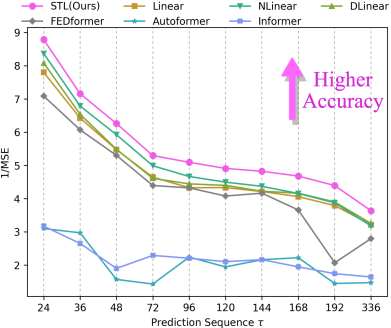
Spatiotemporal-Linear - Universal Multivariate Time Series Forecasting
Research Project
Novel forecasting model using Residual Neural Networks with Spatial Attention